Engineering
The robot project brings together mechanical design, 3D printing, electronics and software. Explore the disciplines below — from documented workshop progress to systems planned for future development.
3D Design
Blender-based modelling, geometry revisions and design-to-build iteration. The existing development journal documents practical work on servo-joint shapes and fit.
Explore 3D Design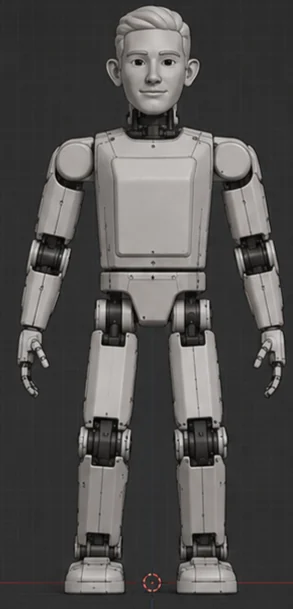
3D Printing
From digital models to real parts. The original project record describes PETG printing, servo mounts and repeated adjustments during construction.
Explore 3D Printing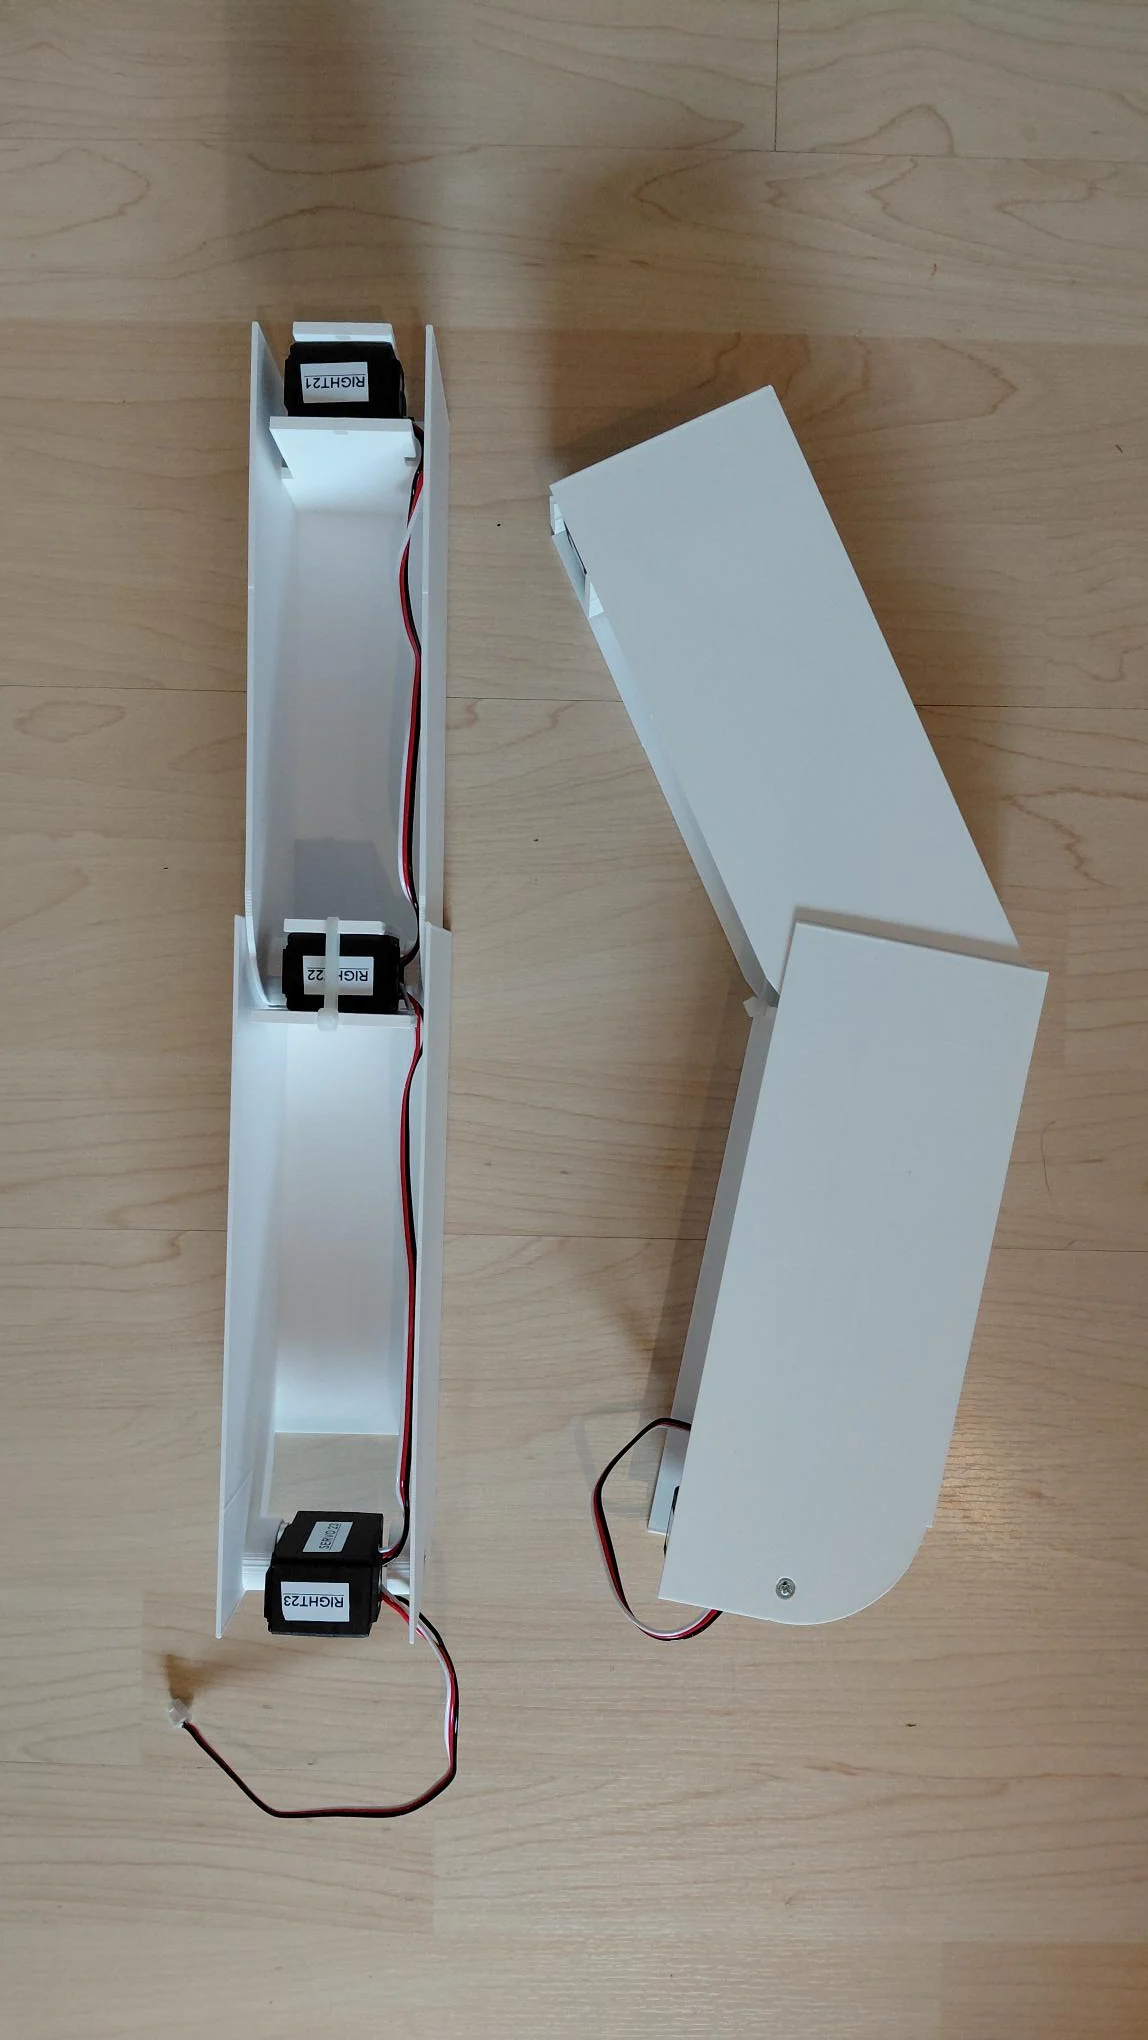
Mechanics
Joints, linkages, mounting geometry and physical assembly. This area is ready for future measurements, engineering drawings and mechanical tests.
Explore Mechanics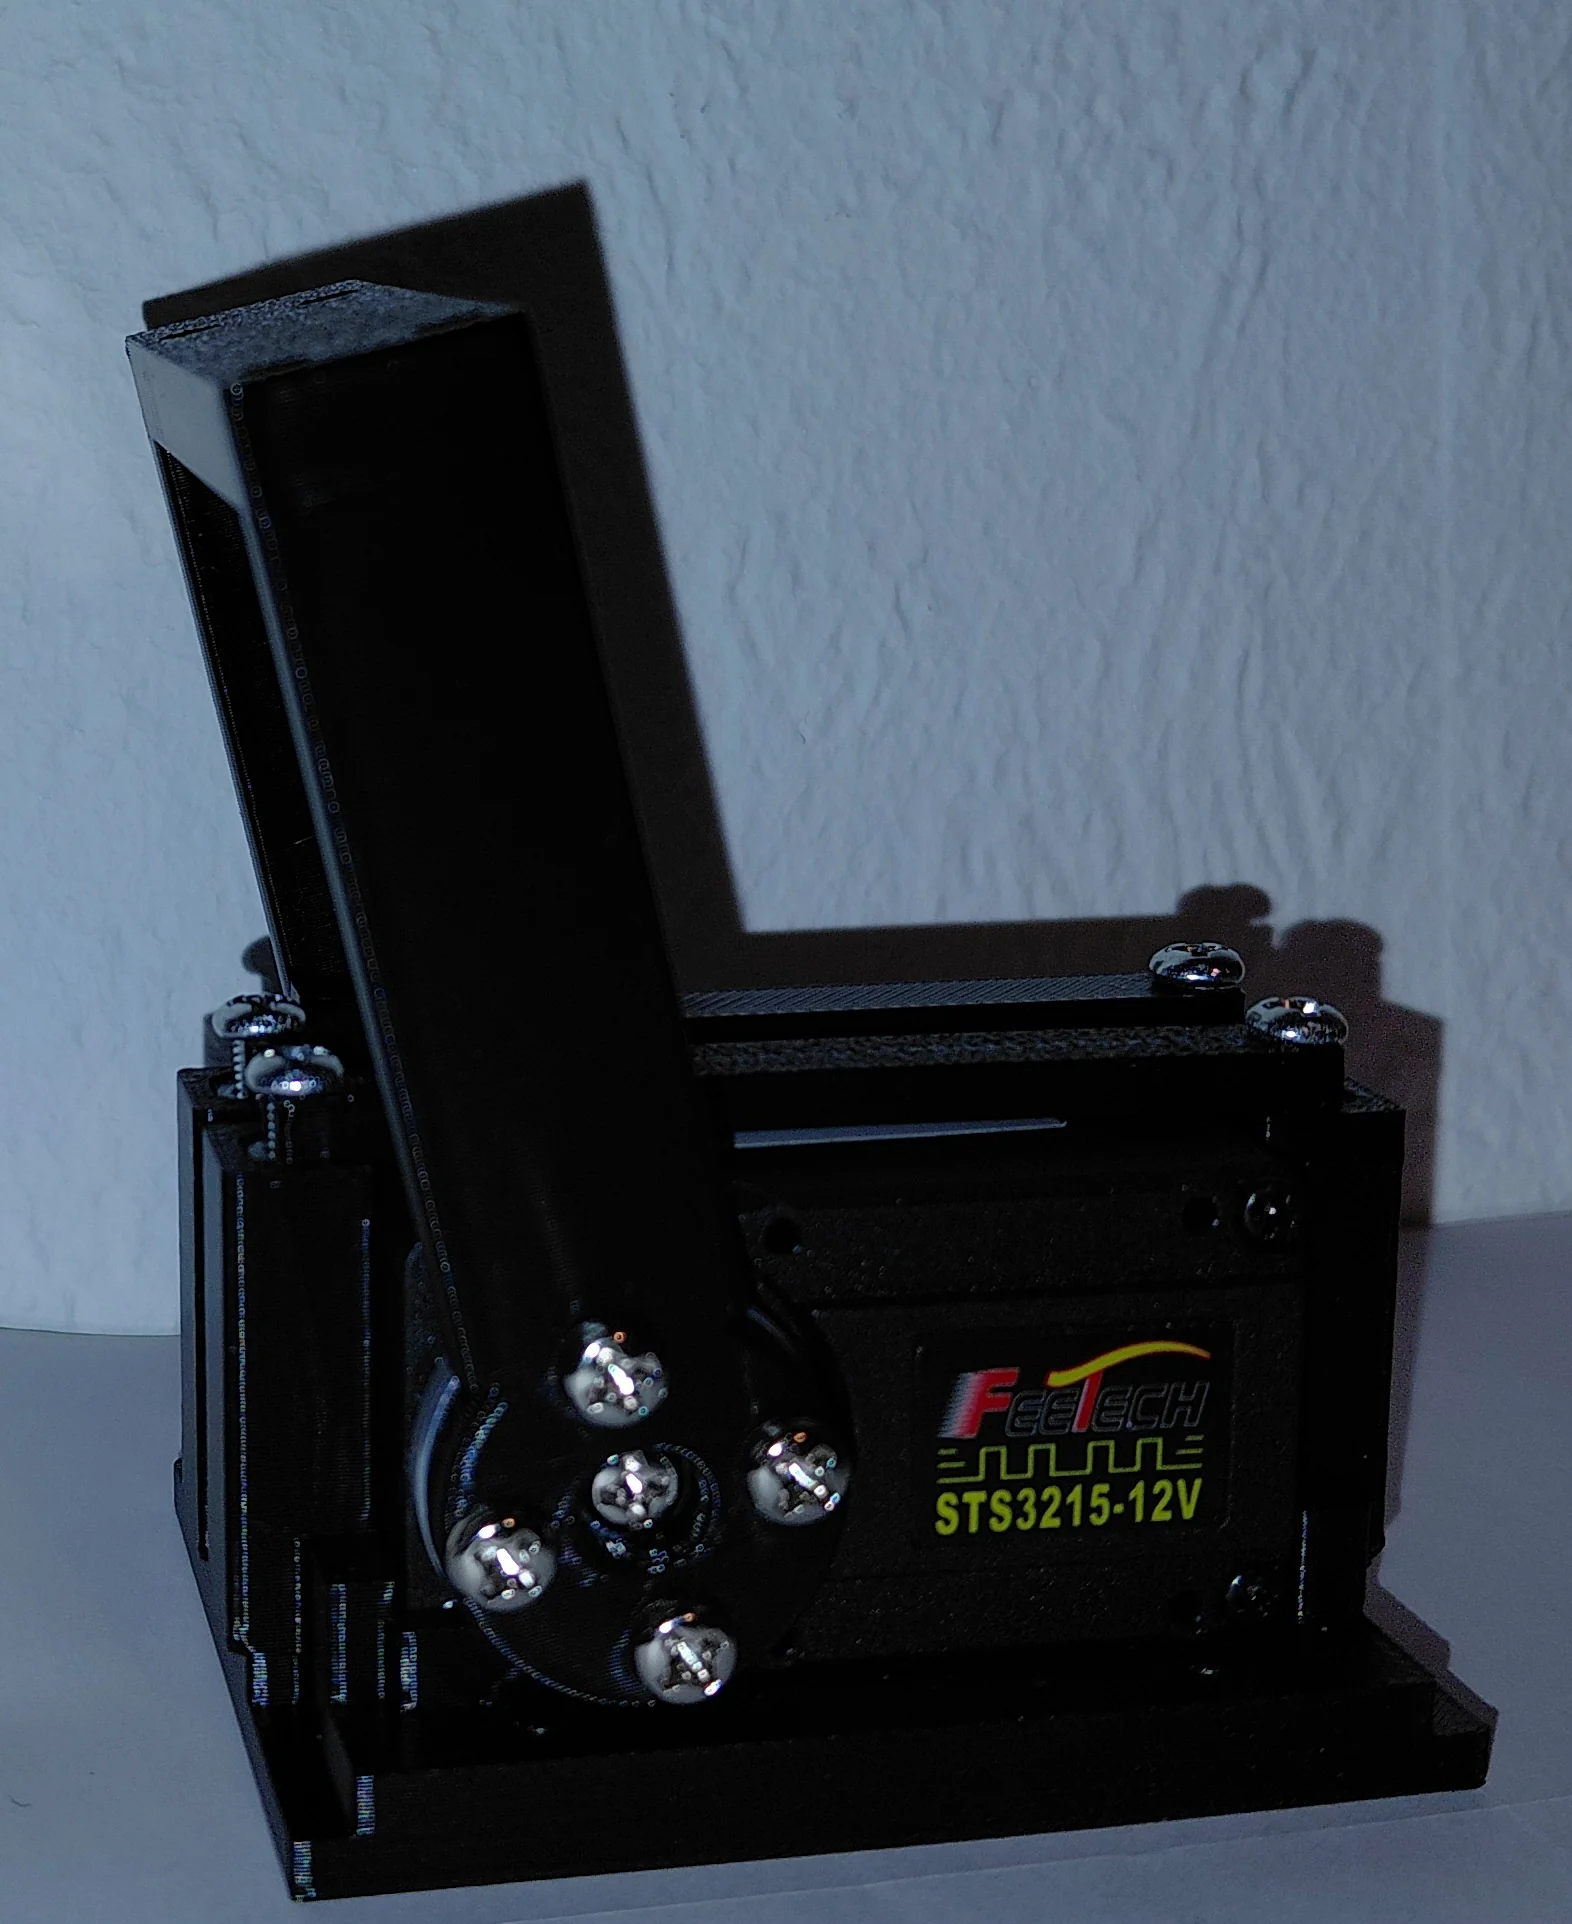
Electronics
The documented first servo tests, controller interfaces and power arrangements — together with a clear distinction between equipment on hand and planned components.
Explore Electronics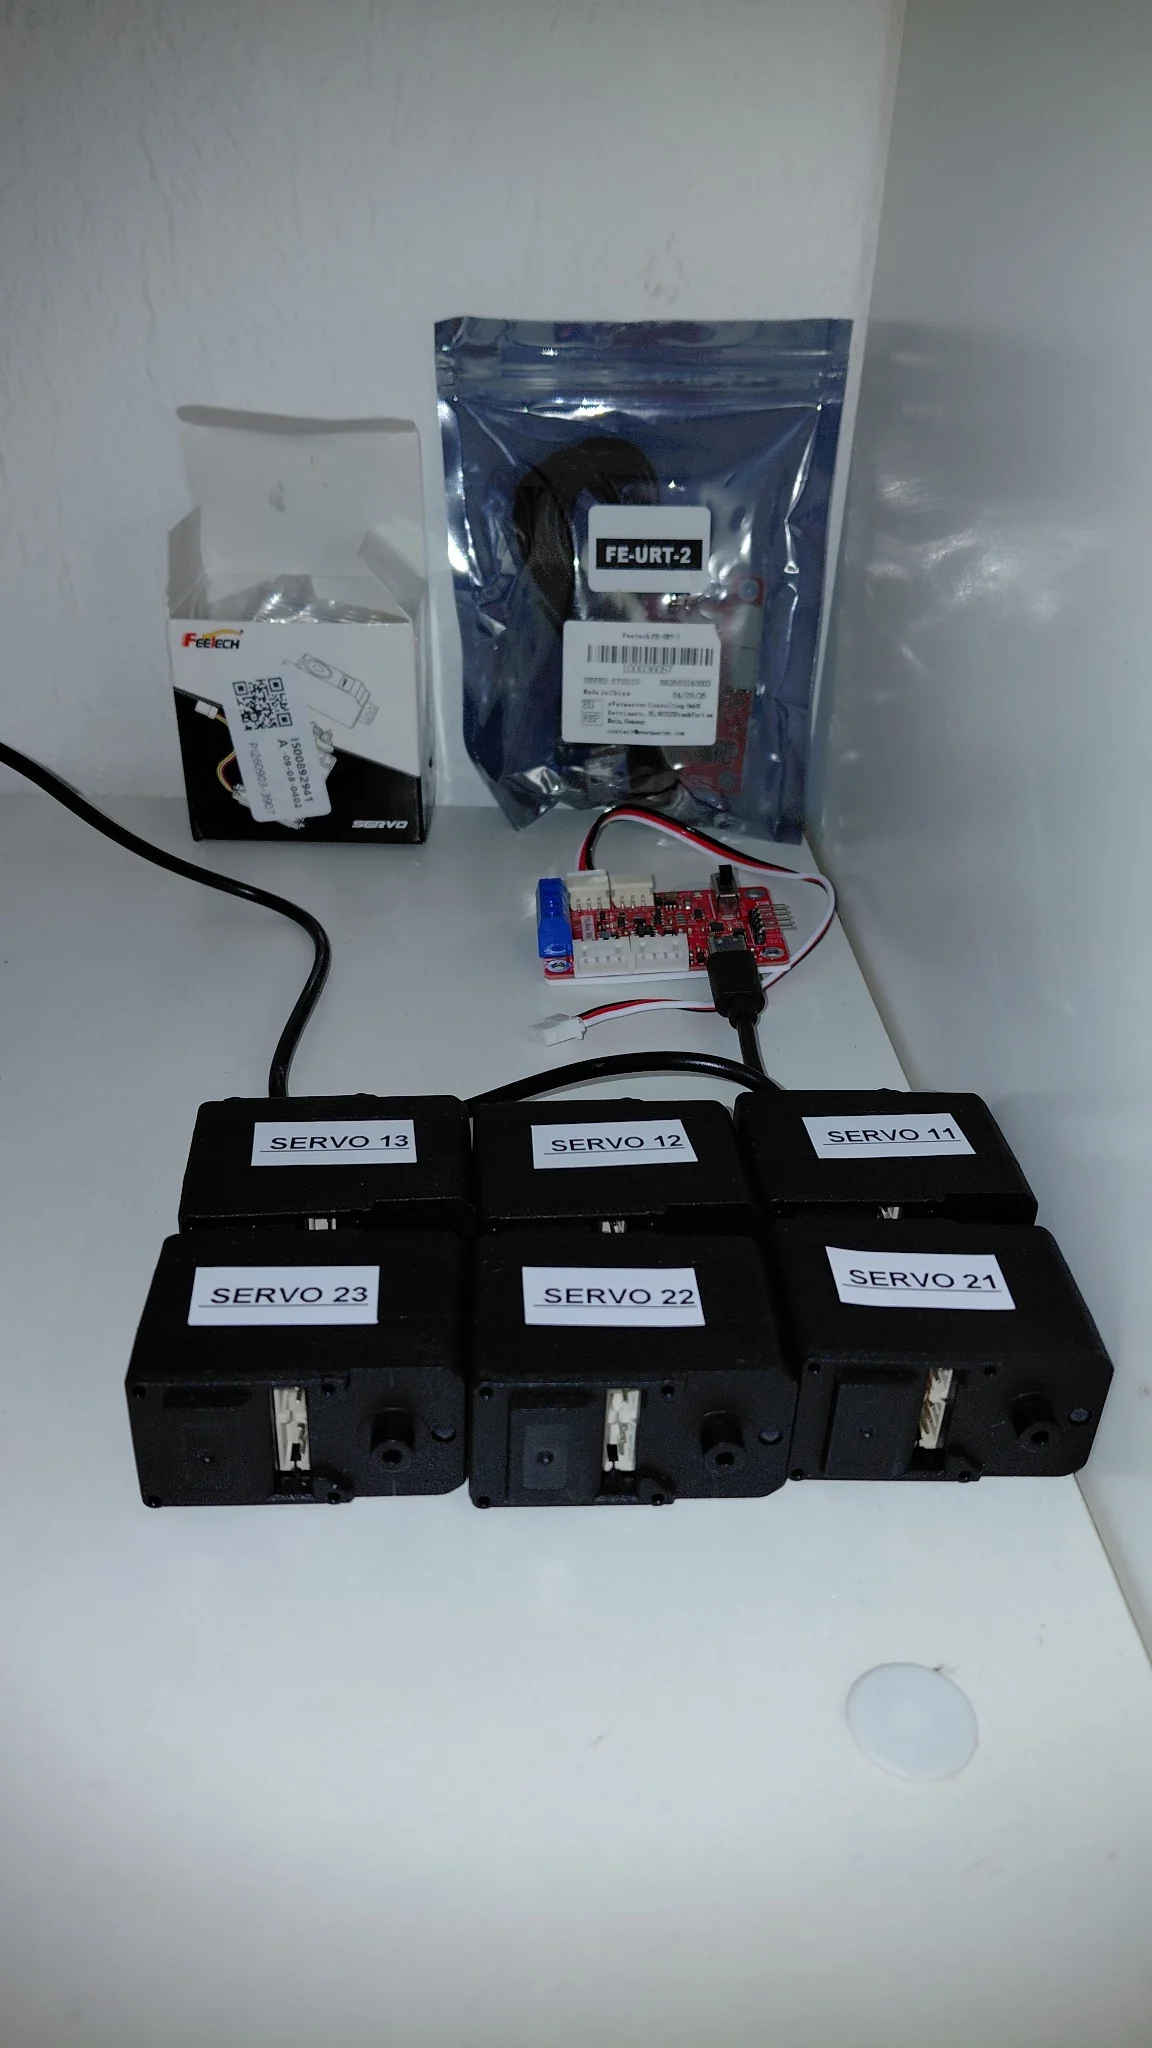
Software
A dedicated section for the robot's software architecture, source code and control logic as verified work becomes ready to publish.
Explore SoftwareArtificial Intelligence
A home for actual AI experiments, perception and interaction work when implemented and tested. Future goals are not presented as completed features.
Explore Artificial Intelligence