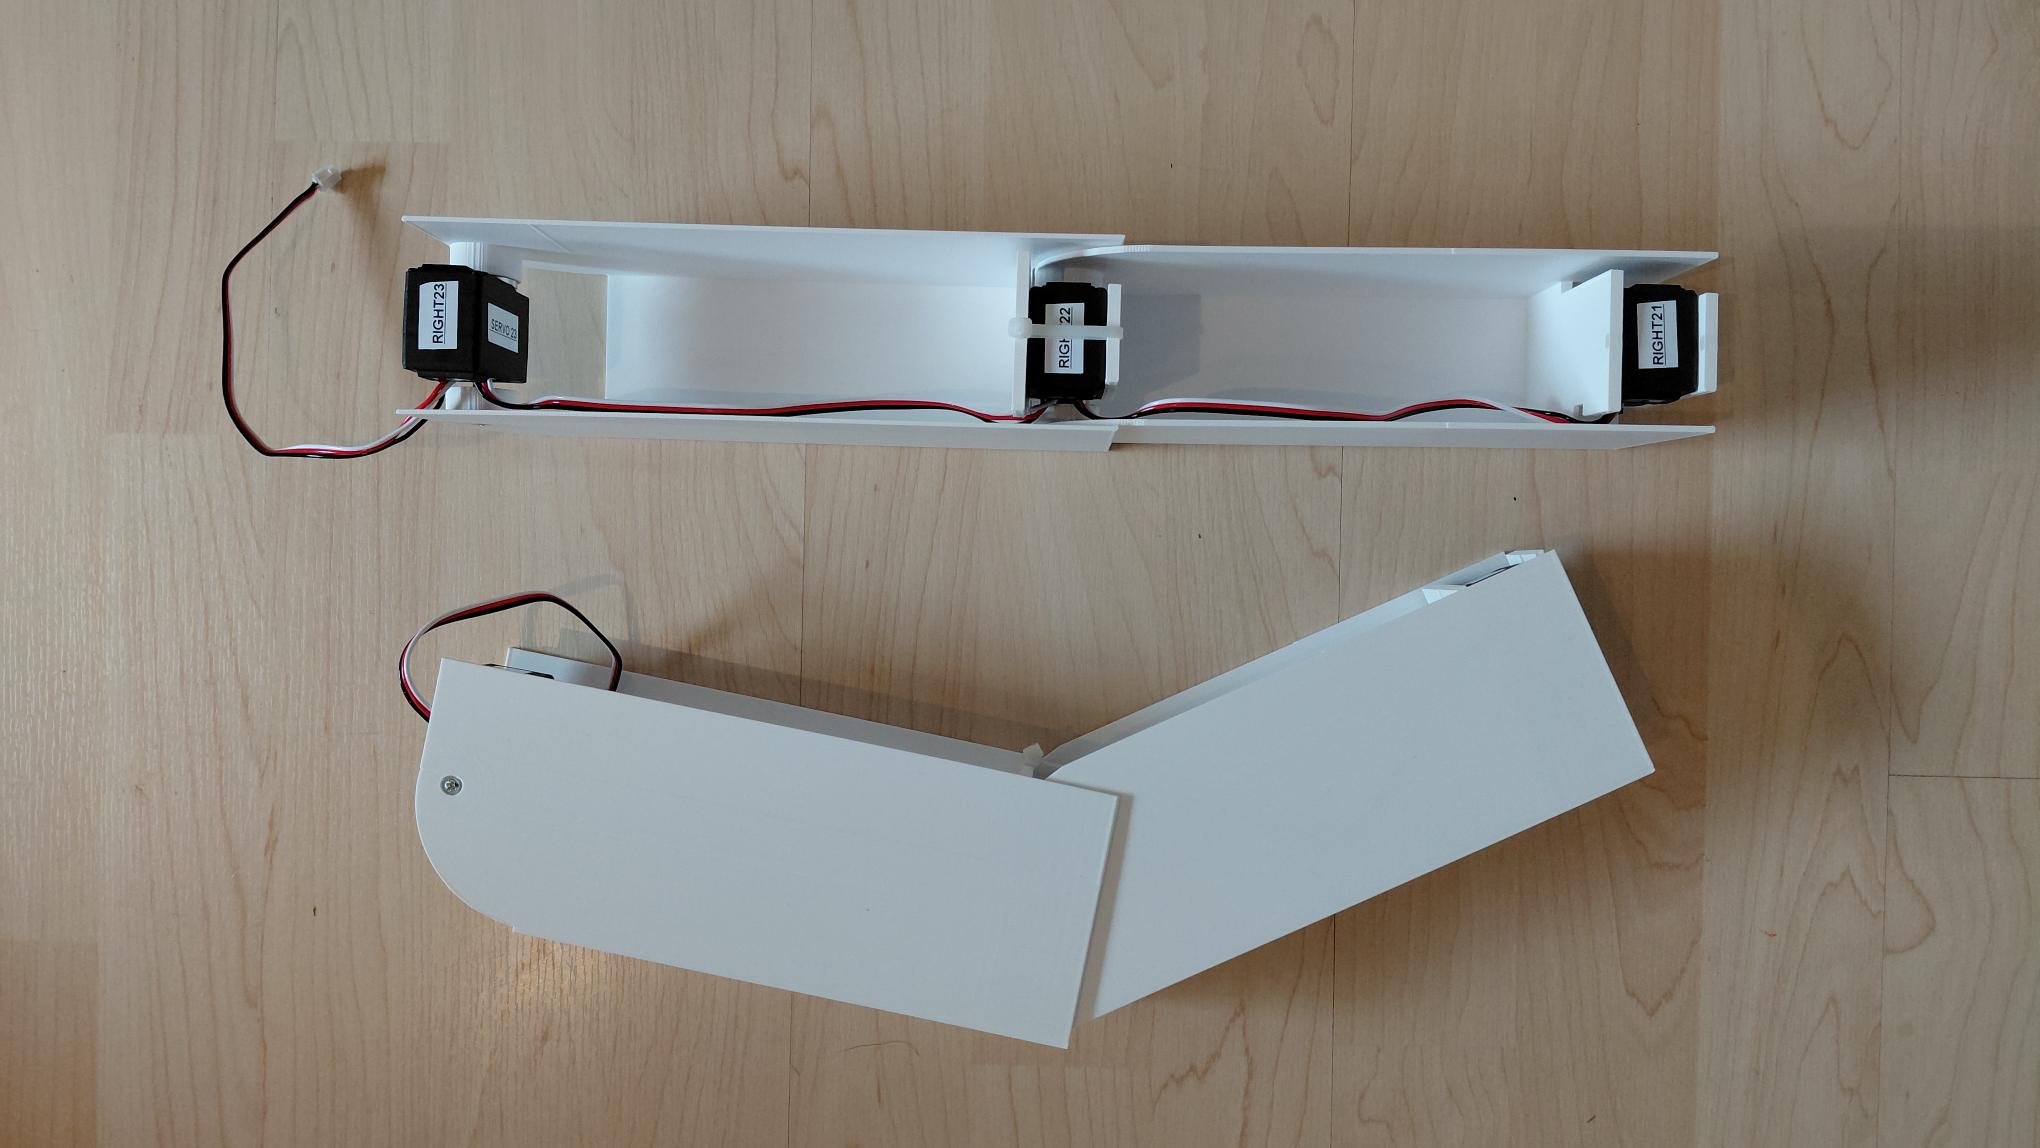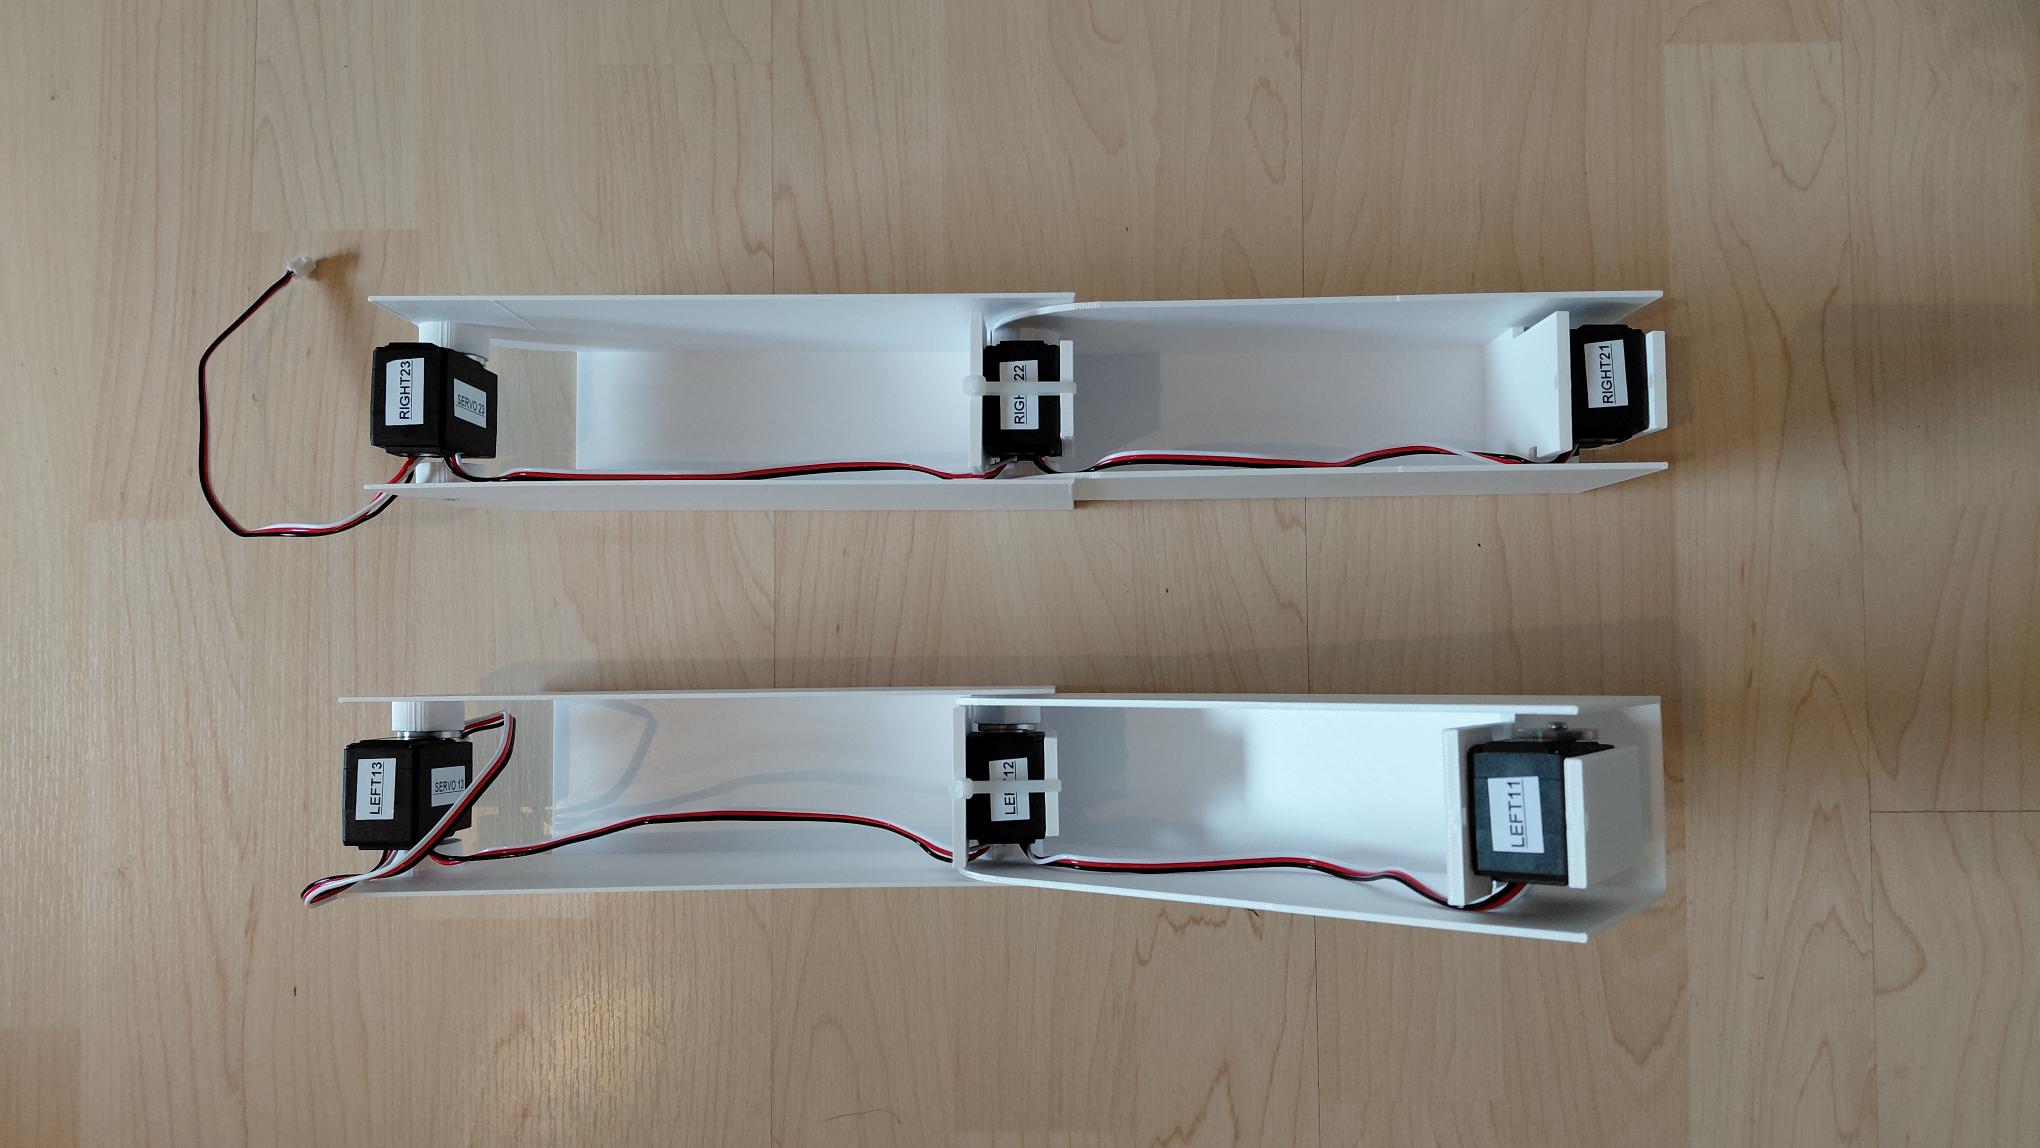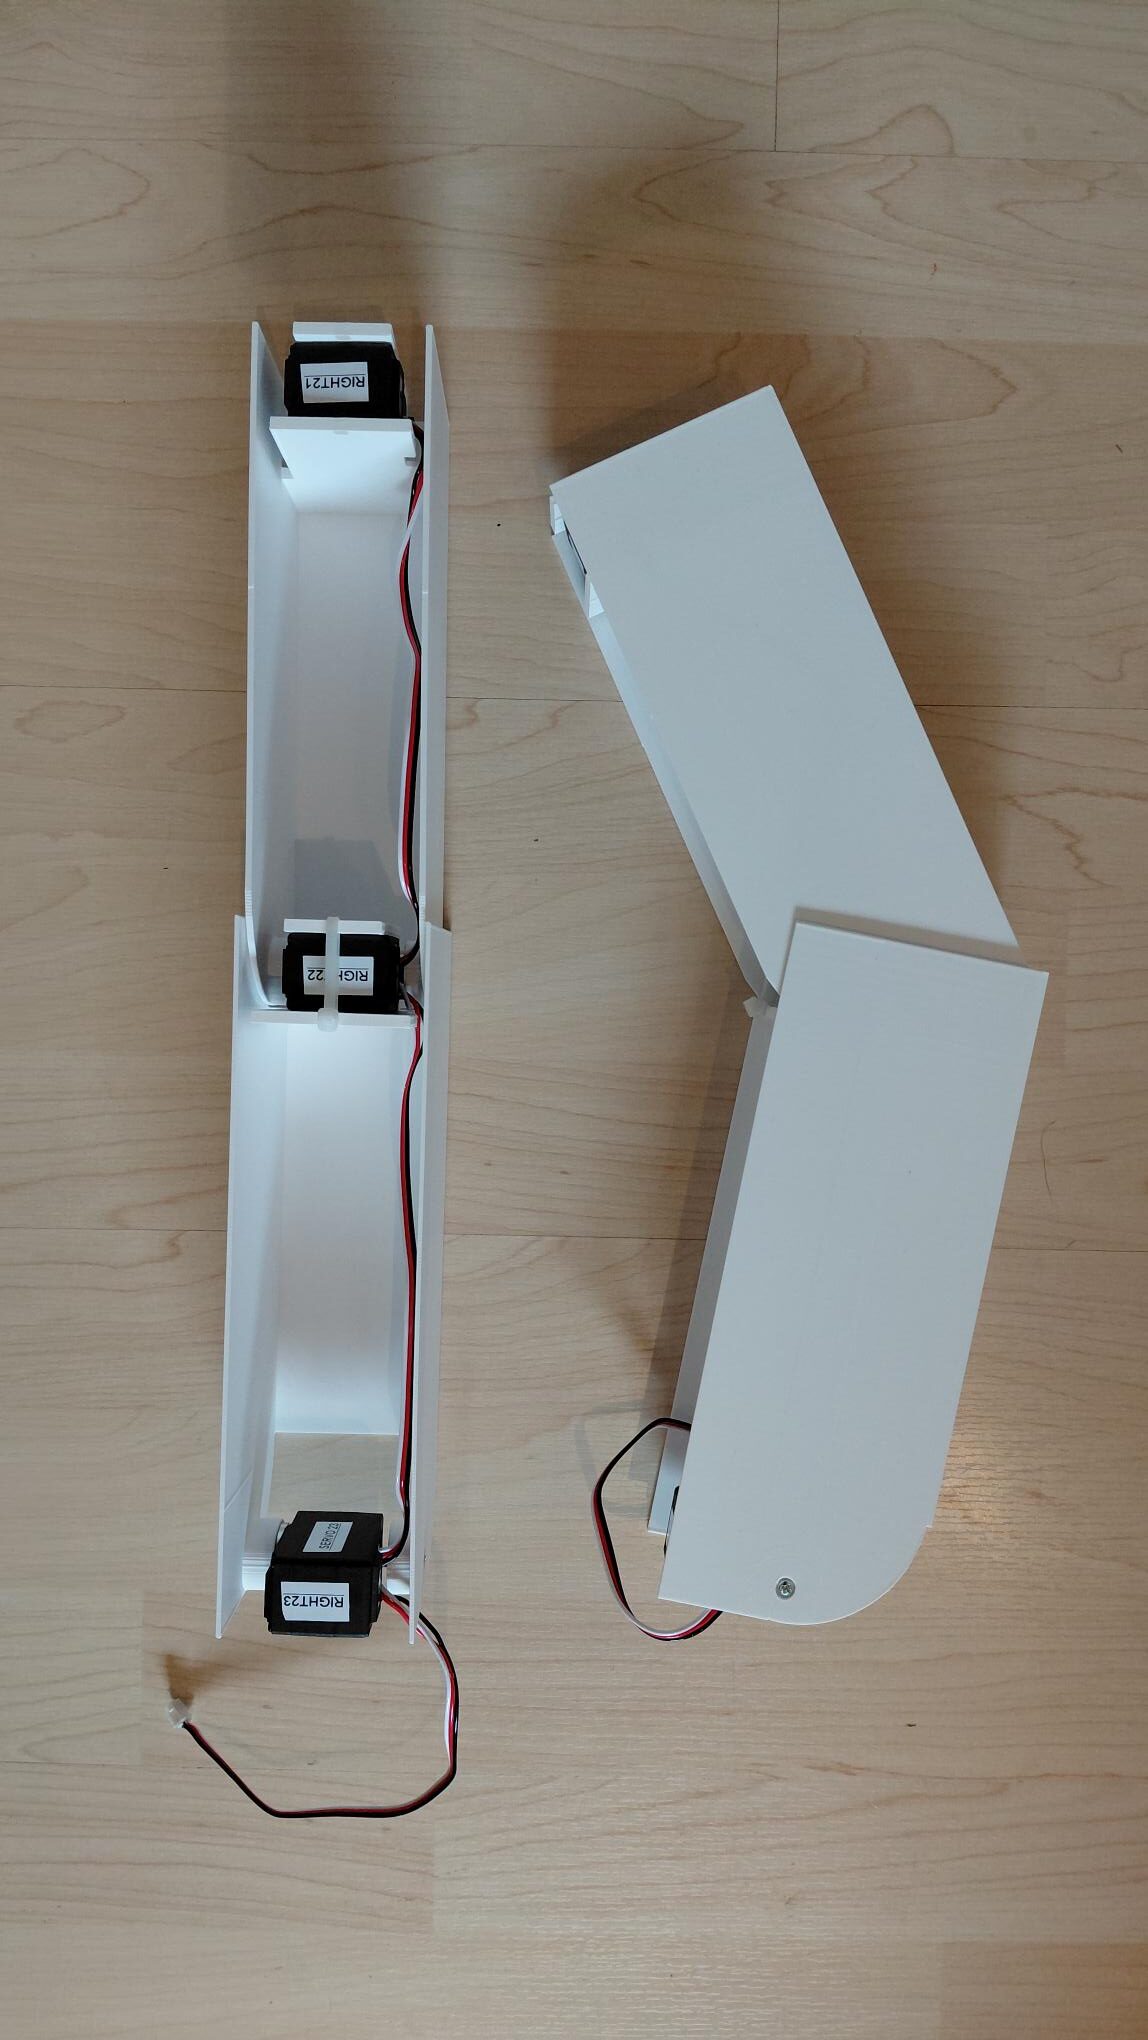
A lot of testing and printing, and changing.
Initial servo holder for knee joints, ended up scrapped, and the servo joint to be part of thighs, shins and feets.
Servos were set up with movement limits for each joint in the leg.
Installed in the MASTER A revisional setup for the plegs, just pending 7 more hours of printing the feets, then 6 hours of printing the connecting pelvis to connect both legs to a common point for retesting movements and limits.
Many fun hours, doing, redoing, printing, scrapping updating and re-printing.
Looking forwards to have the whole MASTER A Robot printed.
From there, each component can be updated to be more human like in shape.
After full robot printed and balancing is working, it is time for see/hear/talk with AI interface to online API.
Pheeew, long way to go, but exciting it is!